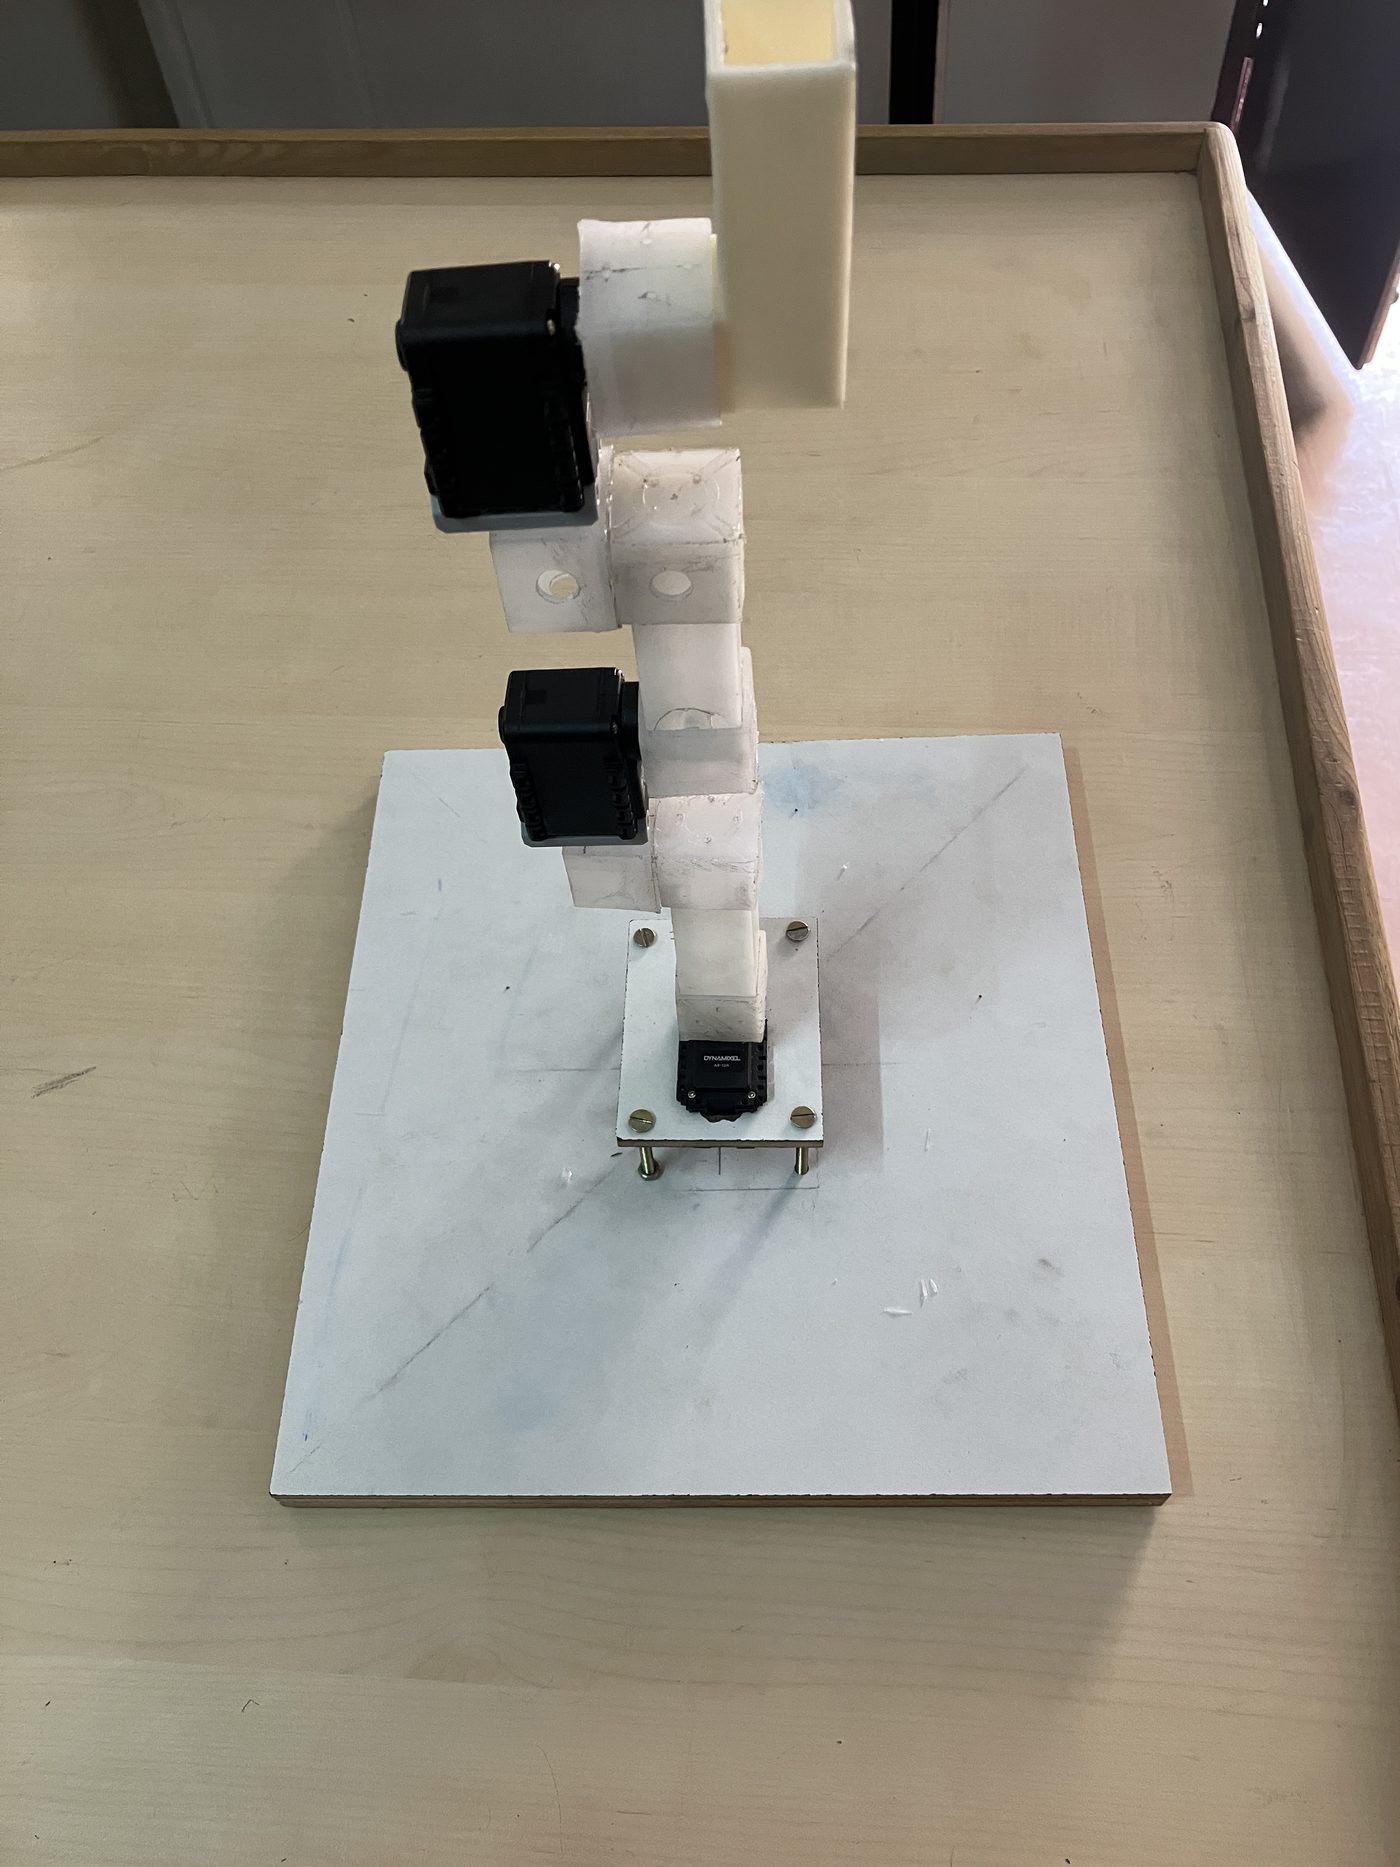
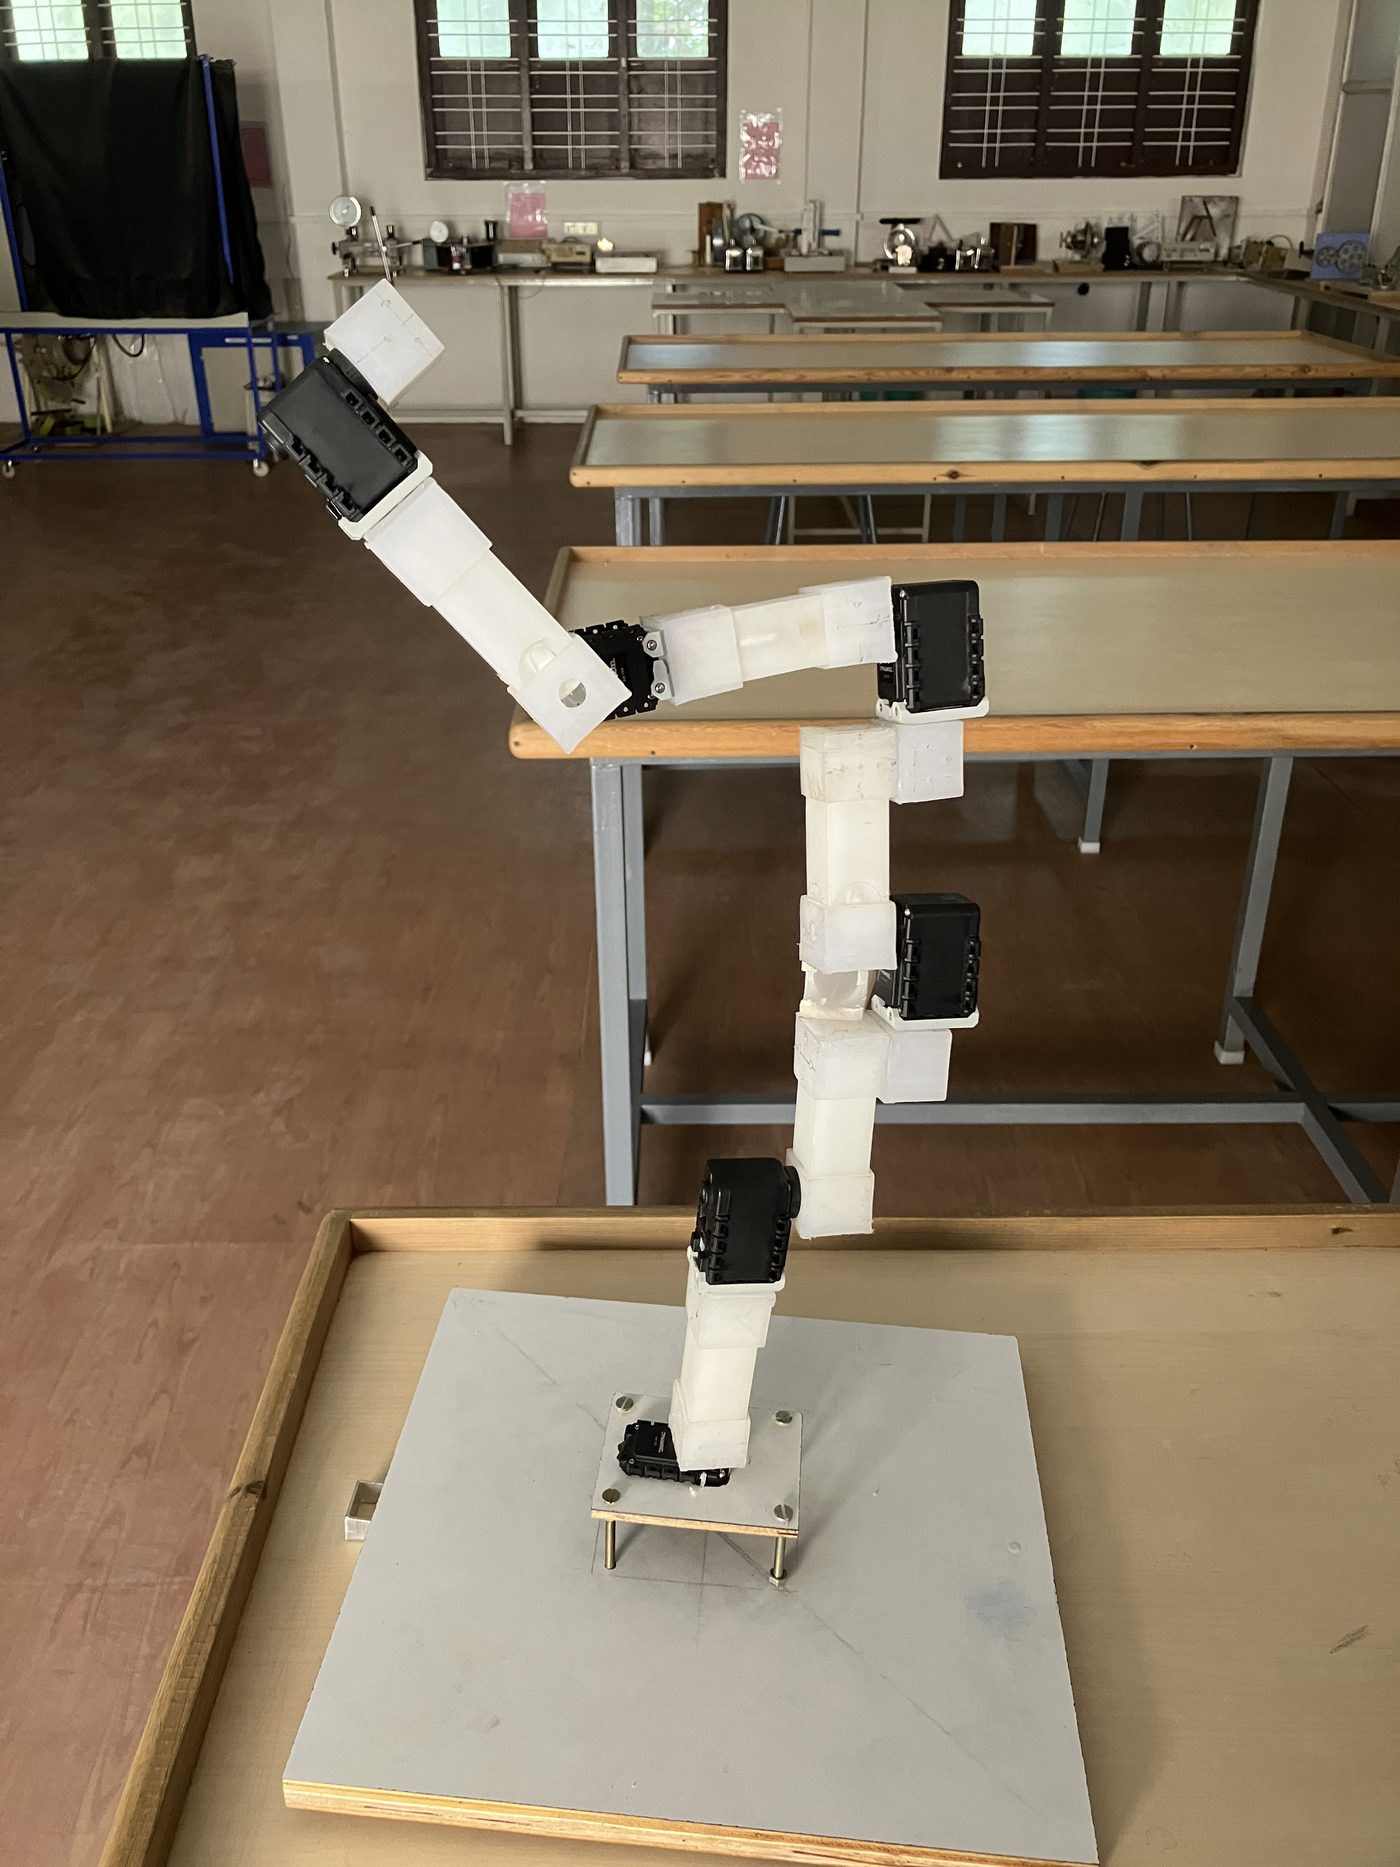
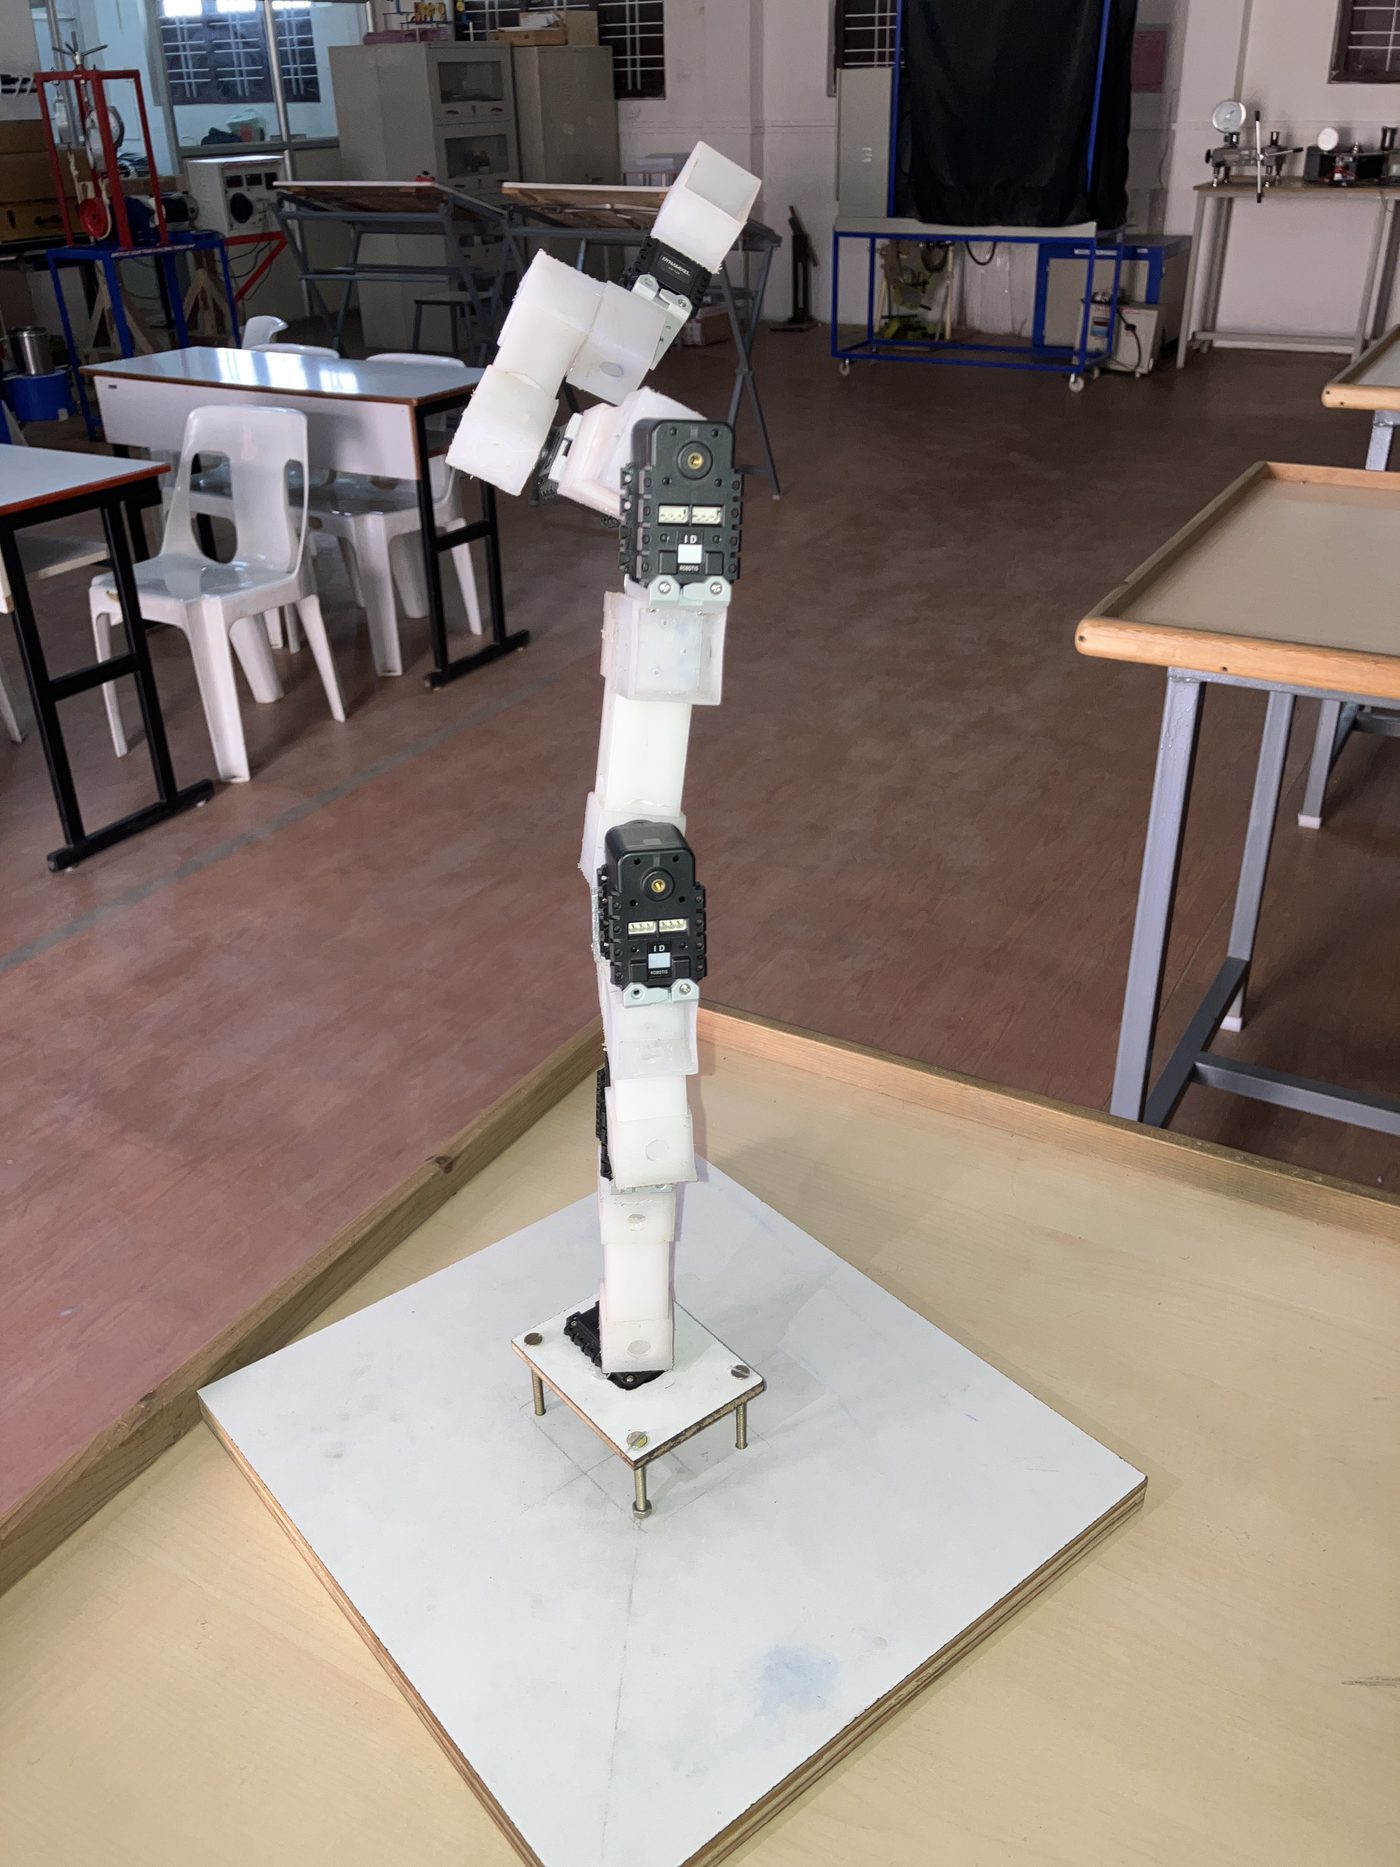
Modular Serial-Chain Robotic Arm with Plug-and-Play Architecture
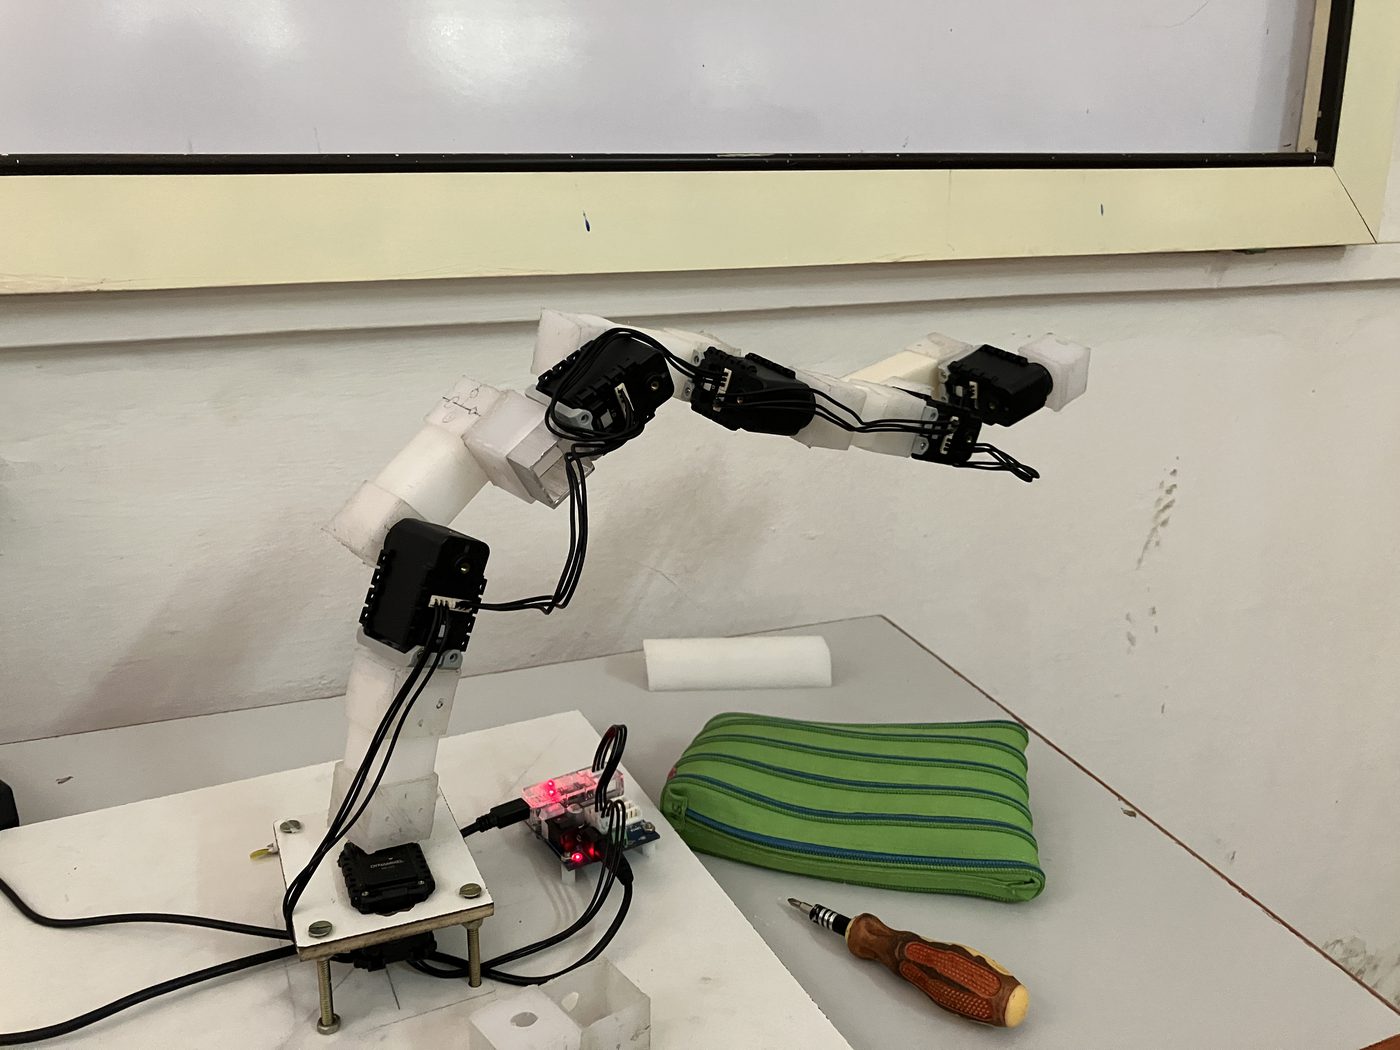
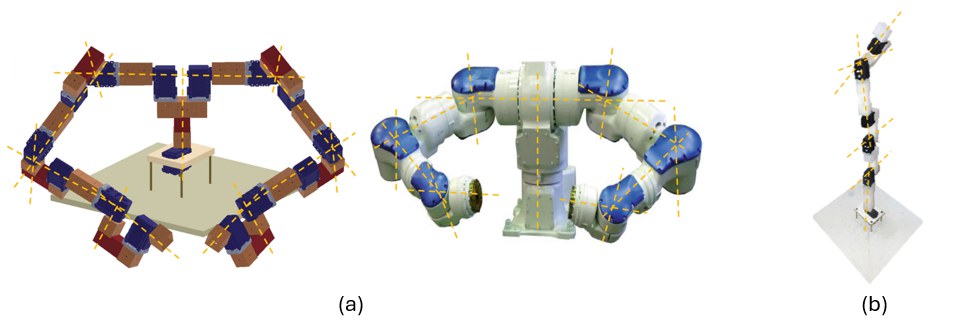
During my undergraduate research, I worked in a team for a project that started out as simply building a robotic arm. While working on it, I discovered that the same idea could be made modular, so that the same parts could be reused to create different articulated industrial robot architectures instead of one fixed arm. I found this very interesting because it made the project more useful and also economical.
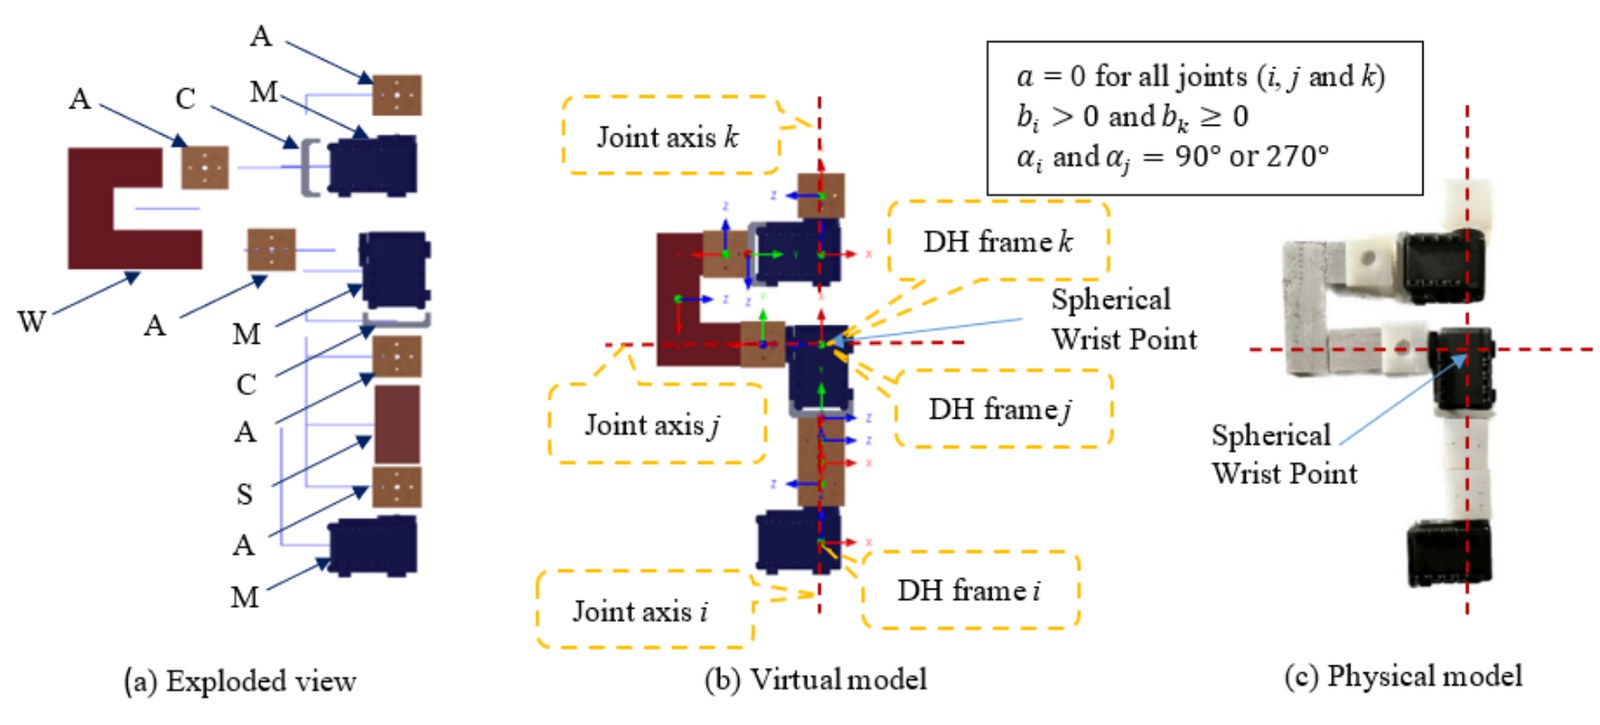
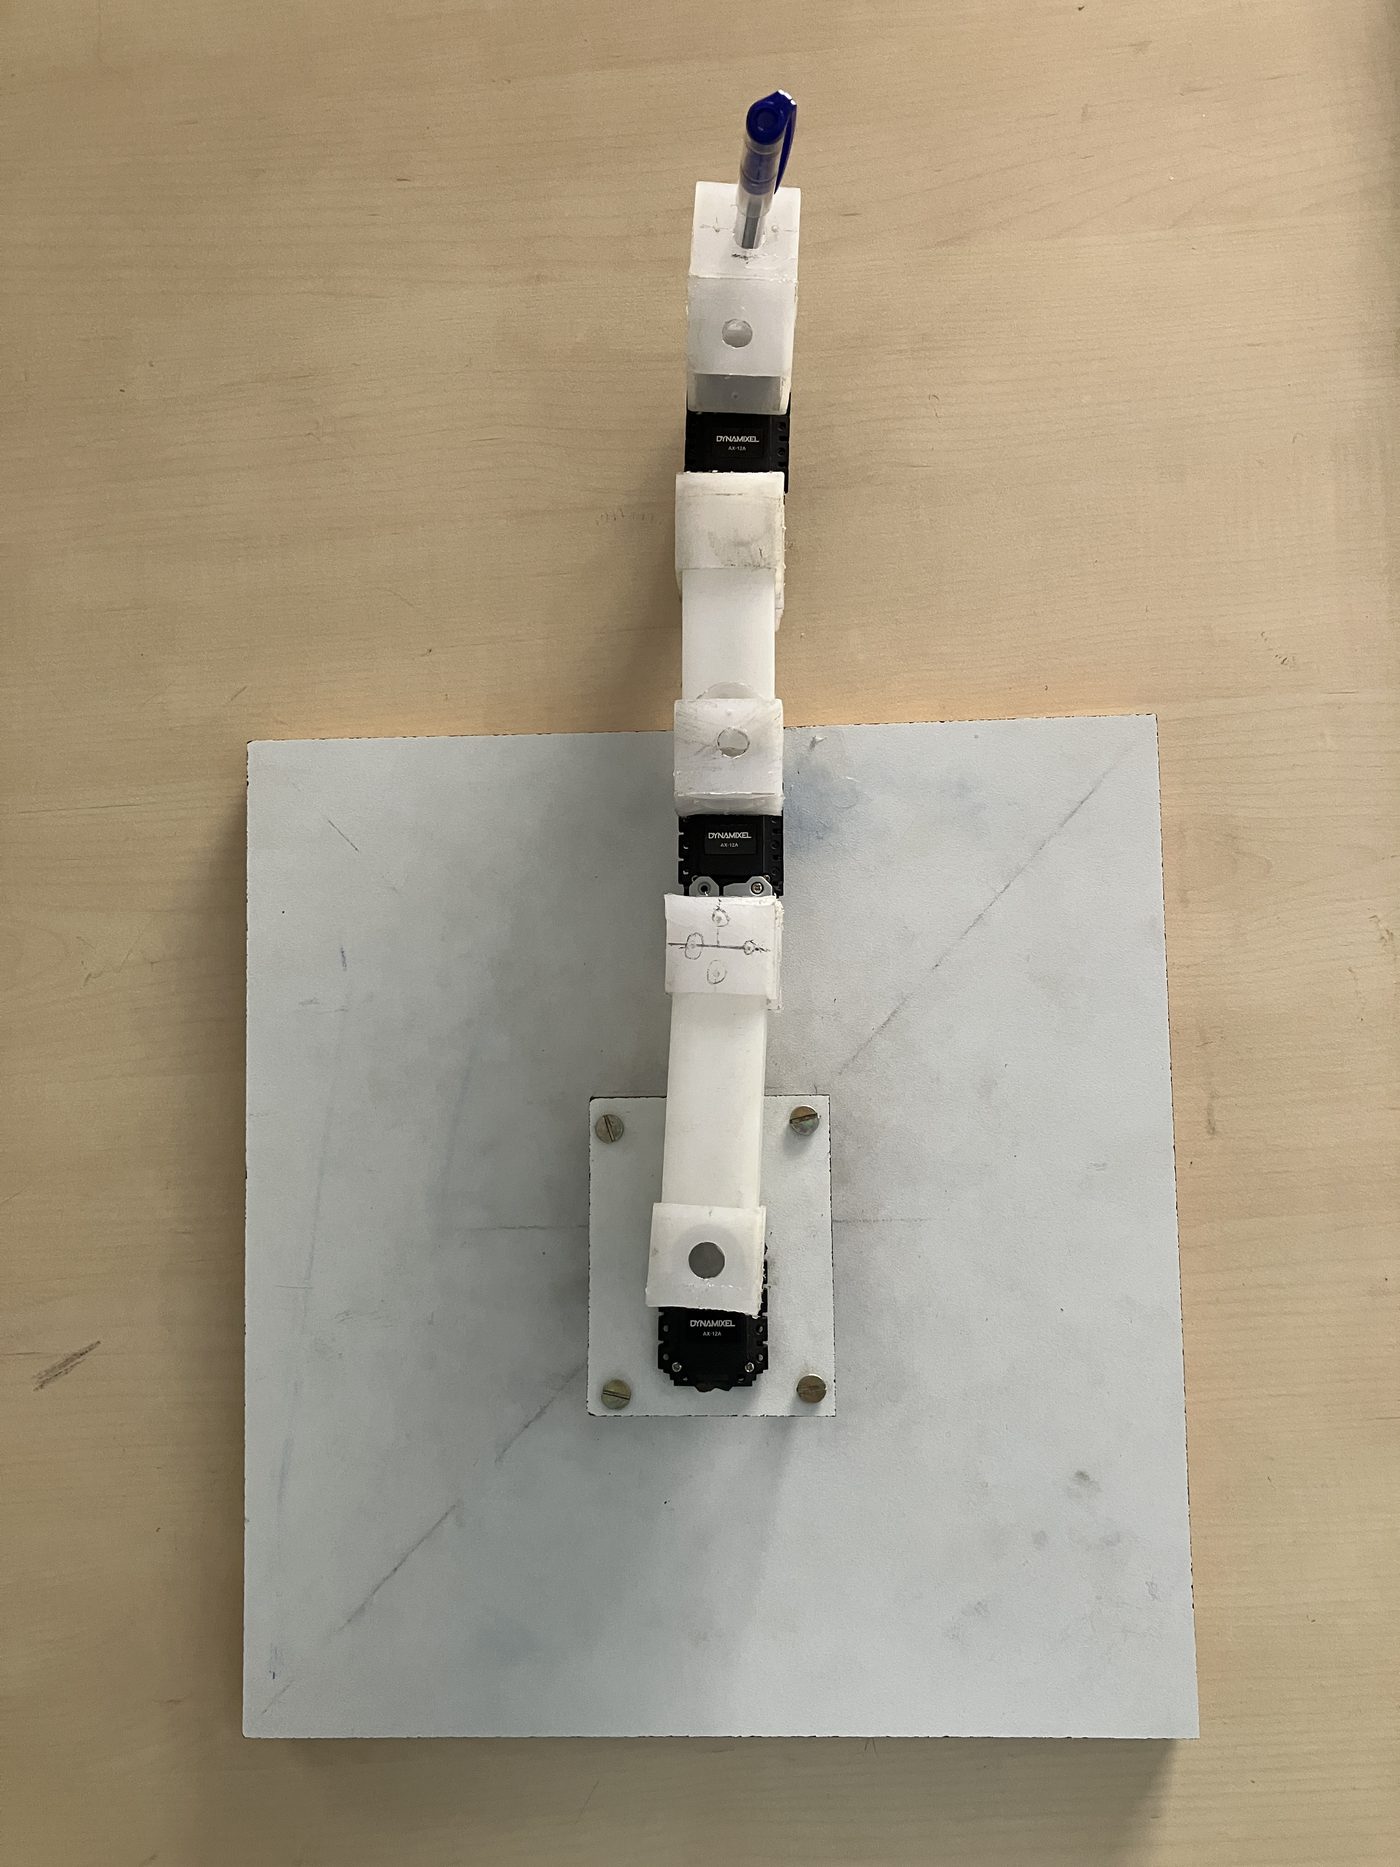
After this discovery, I worked on designing modular units using off-the-shelf materials. I created physical prototypes and iterated the design to improve the positioning accuracy of the arm. My work involved integrating the mechanical design, hardware and software together. This included the modular links, adapters, servo motors, motor controller and the software interface.
I also worked on creating a Windows application that connected the physical arm with RoboAnalyzer, a 3D model-based software used to teach and learn robotics concepts. The system was patented and is now being moved towards commercialization, with the aim of being sold to universities as a robotics learning platform.